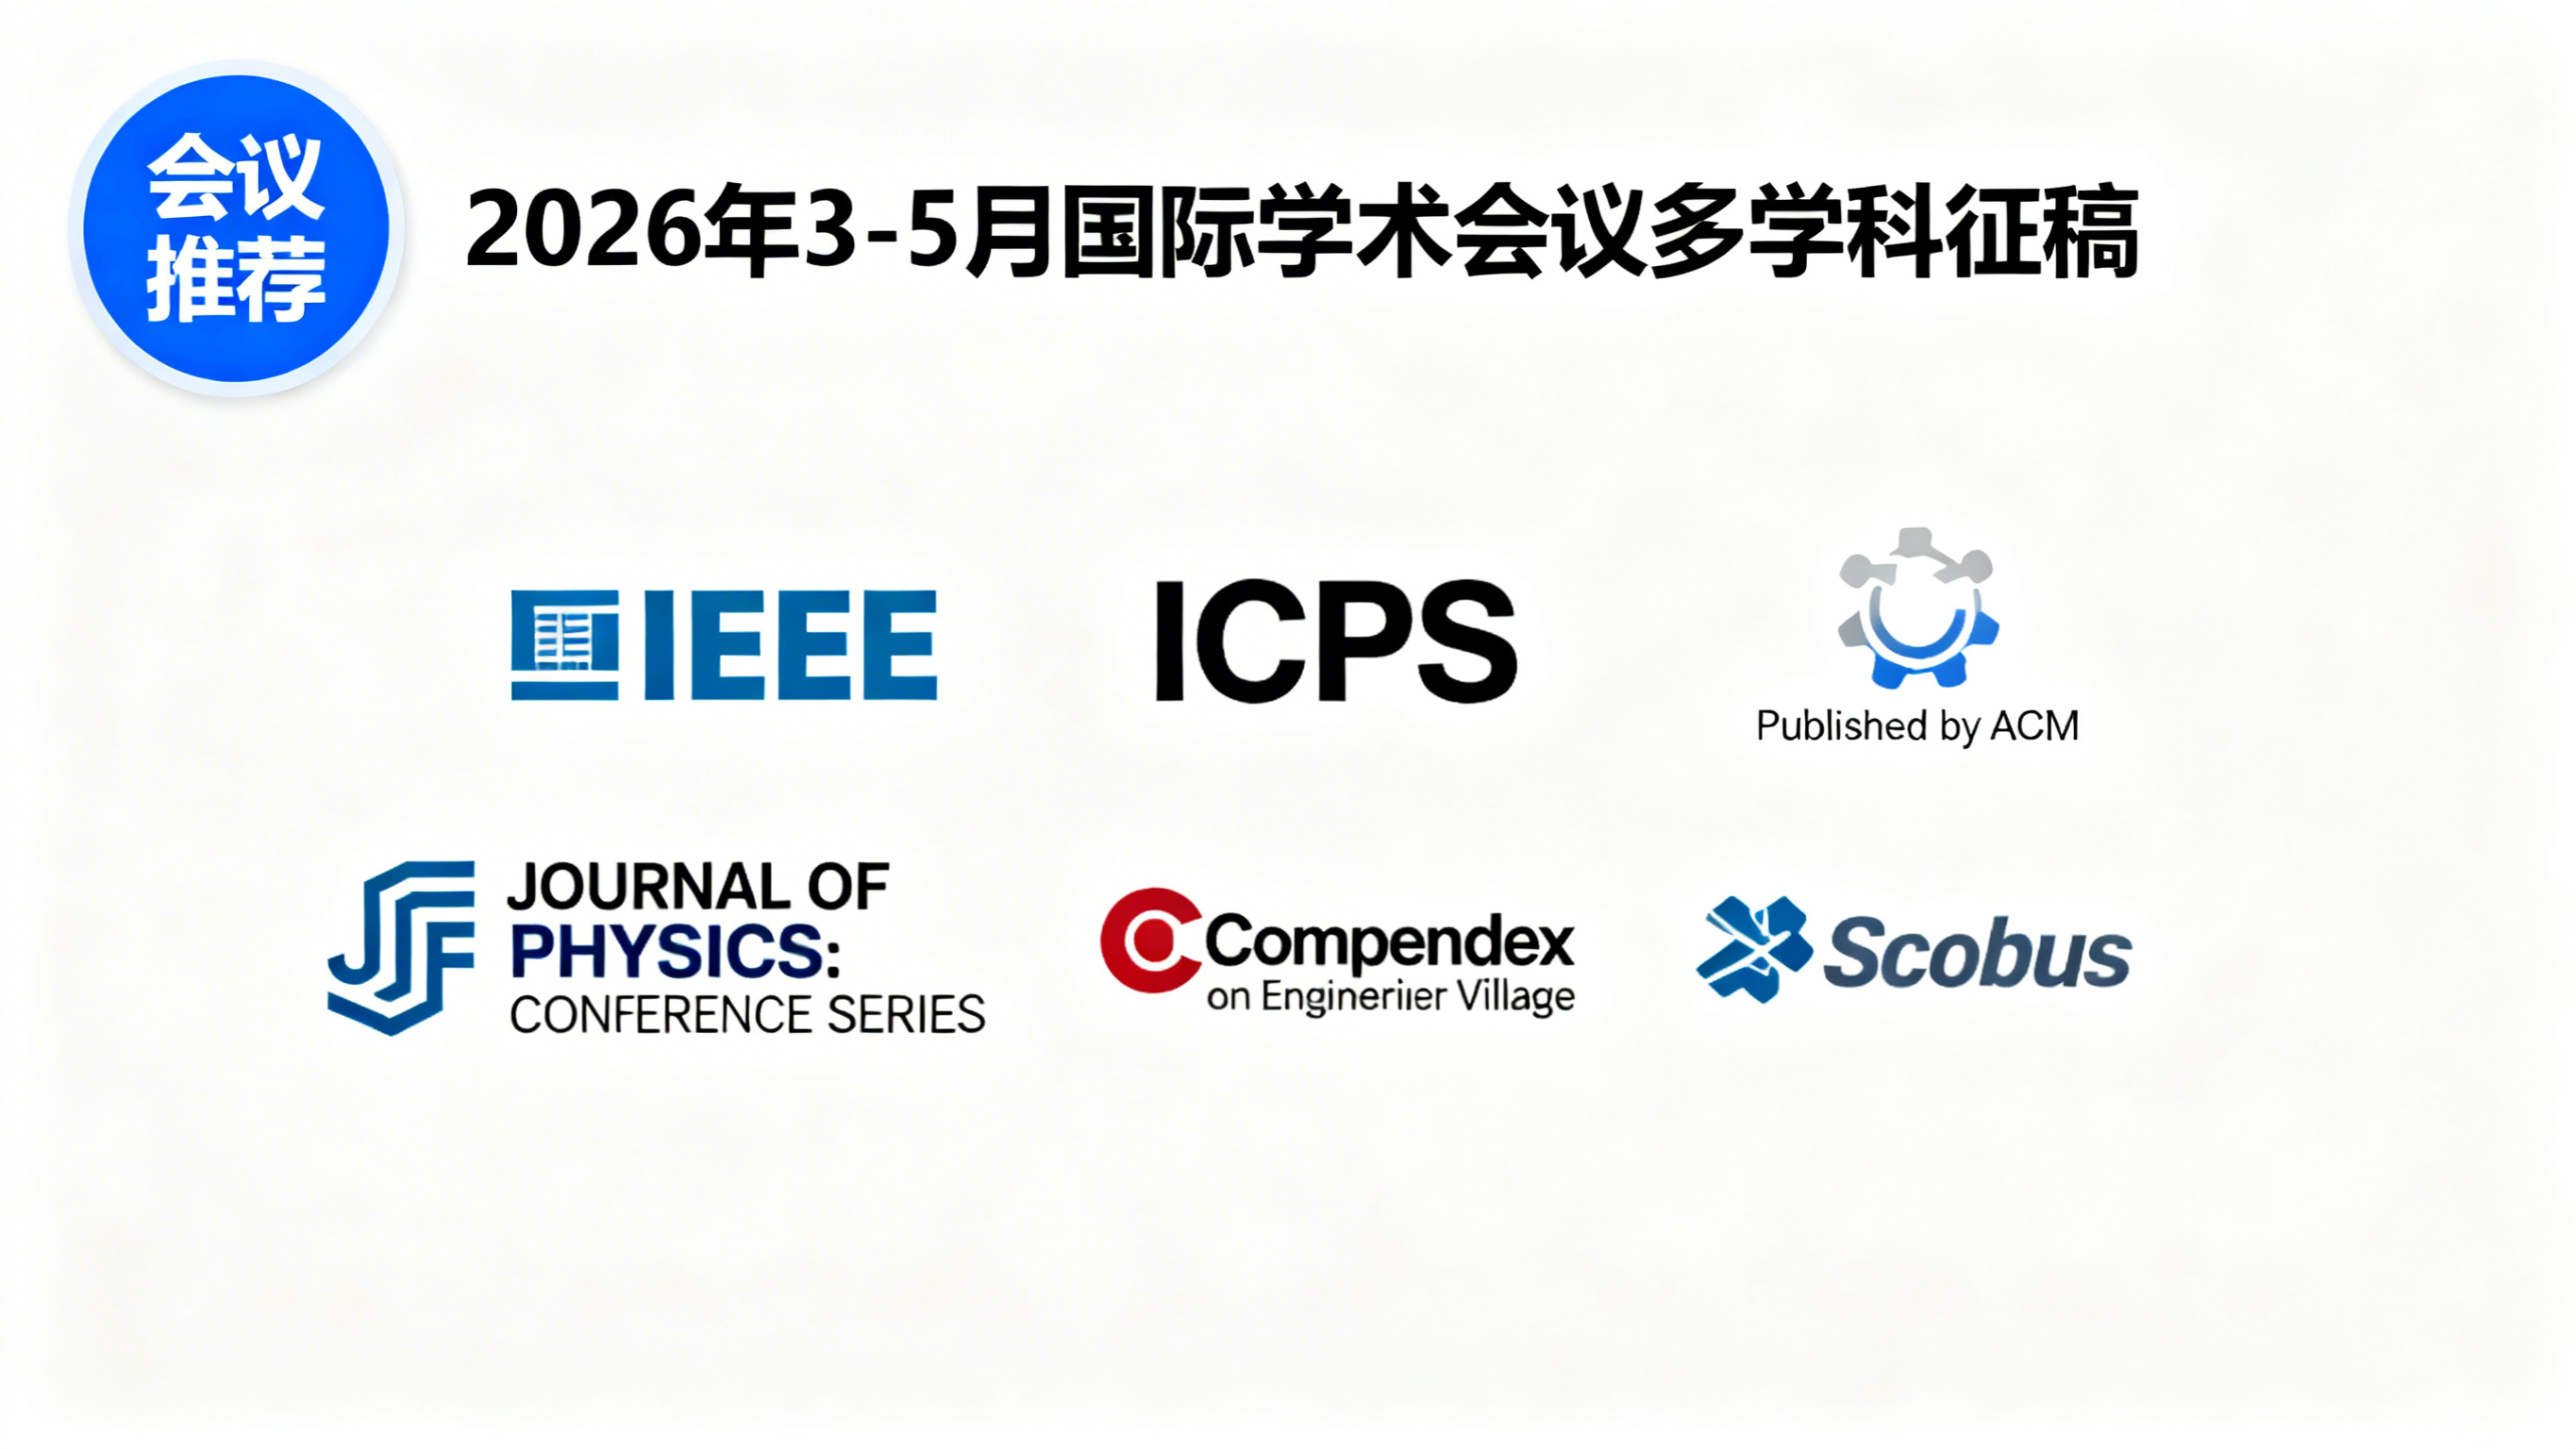

白色背景的学术征稿宣传图,左上角有蓝色圆形标识,标识内文字是"… - 图片创意预览

白色背景的学术征稿宣传图,左上角有蓝色圆形标识,标识内文字是"…

白色背景的学术征稿宣传图,左上角有蓝色圆形标识,标识内文字是"会议推荐",图片上方居中位置有文字"2026年3-5月国际学术会议多学科征稿",画面中间包含IEEE、ICPS(标注Published b
用户头像

1q0gqvr47p1...

2026.03.12
学术信息海报第一页,标题为"学界动向——认知神经科学与人机共生 (Human-AI Symbiosis)",副标题"探讨从'工具使用'向'智能协作'的理论转型"。整体分为三个板块: 左侧栏:宏观趋势与政策核心方向:列出"神经人因学 (Neuroergonomics):利用脑机接口(BCI)和便携式脑成像技术监控工作负荷。可解释AI (XAI) 与信任建模:研究人类如何建立对算法决策的合理信任。道德与算法偏见:探讨人因干预在算法公平性中的学术地位。",下方是关键人物:"Raja Parasuraman:神经人因学奠基人,其理论持续影响当下的自动化研究。Ben Shneiderman:倡导'以人为本的AI(HCAI)',平衡人类控制与计算机自动化。",再下方是主要政策/刊物:"IEEE Transactions on Human-Machine Systems 前沿课题。欧盟《人工智能法案》(AI Act)对人机交互安全性的最新学术指引。" 中间板块:标题"前沿研究案例",国内研究案例:"清华/浙大 脑机交互实验室 突破点:异步非侵入式BCI在残障人士辅助系统中的应用,实现高精度的意图识别。解析:将认知模型转化为控制指令,突破传统肢体交互的物理极限。",国际研究案例:"斯坦福 Human-Centered AI (HAI) 中心 研究点:'情境感知的协作机器人(Cobots)'。解析:机器人通过眼动追踪和生理电信号判断工人的疲劳状态,动态调整协作步调。" 右侧板块:标题"学术演进对比与技术矩阵",列出技术应用对比表: 维度 | 传统人因工程 | 前沿人因工程 (HFE 4.0) 交互媒介 | 物理按键/屏幕 | 脑机/语音/手势/眼动 评估手段 | 问卷/主观量表 | 实时神经反馈/生理参数 人机关系 | 操作者与工具 | 协作伙伴与共生体 保持参考图的学术信息排版风格,米黄色背景,搭配浅蓝色和浅黄色信息块,清晰图文排版,学术简洁风格,信息完整清晰。学术信息海报第一页,标题为"学界动向——认知神经科学与人机共生 (Human-AI Symbiosis)",副标题"探讨从'工具使用'向'智能协作'的理论转型"。整体分为三个板块:
左侧栏:宏观趋势与政策核心方向:列出"神经人因学 (Neuroergonomics):利用脑机接口(BCI)和便携式脑成像技术监控工作负荷。可解释AI (XAI) 与信任建模:研究人类如何建立对算法决策的合理信任。道德与算法偏见:探讨人因干预在算法公平性中的学术地位。",下方是关键人物:"Raja Parasuraman:神经人因学奠基人,其理论持续影响当下的自动化研究。Ben Shneiderman:倡导'以人为本的AI(HCAI)',平衡人类控制与计算机自动化。",再下方是主要政策/刊物:"IEEE Transactions on Human-Machine Systems 前沿课题。欧盟《人工智能法案》(AI Act)对人机交互安全性的最新学术指引。"
中间板块:标题"前沿研究案例",国内研究案例:"清华/浙大 脑机交互实验室 突破点:异步非侵入式BCI在残障人士辅助系统中的应用,实现高精度的意图识别。解析:将认知模型转化为控制指令,突破传统肢体交互的物理极限。",国际研究案例:"斯坦福 Human-Centered AI (HAI) 中心 研究点:'情境感知的协作机器人(Cobots)'。解析:机器人通过眼动追踪和生理电信号判断工人的疲劳状态,动态调整协作步调。"
右侧板块:标题"学术演进对比与技术矩阵",列出技术应用对比表:
维度 | 传统人因工程 | 前沿人因工程 (HFE 4.0)
交互媒介 | 物理按键/屏幕 | 脑机/语音/手势/眼动
评估手段 | 问卷/主观量表 | 实时神经反馈/生理参数
人机关系 | 操作者与工具 | 协作伙伴与共生体
保持参考图的学术信息排版风格,米黄色背景,搭配浅蓝色和浅黄色信息块,清晰图文排版,学术简洁风格,信息完整清晰。
保持原图的整体设计风格和排版布局,橙色虚线边框白色背景,小红书风格信息图。替换所有文字内容为以下新文案,保持原图的图标风格、字体风格、配色方案和整体视觉节奏: 顶部大标题:人文社科申博中介怎么选?2026测评避坑指南 第一梯队标题(红色):第一梯队 | 双核心标杆:强服务体验+强申请结果 第一梯队正文: 优越留学代表,17年人文社科高端PhD服务经验,独立博士事业部人文社科专项小组 核心优势: 签约顾问全部硕博学历,9年以上人文社科顶校申博经验 3000+海外博士师资库覆盖哲学、人文地理、传播学、教育技术等120余细分方向 服务体系:顶校学术深度脑暴+高端博士定制冲刺规划+高阶学术精细化落地+四层高端质控兜底 脑暴环节深挖课程论文、田野调研、会议论文,提炼真实研究缺口 高阶业务:人文社科RP定制、中文核心/会议论文润色、教授套磁、CSC与院校奖学金攻关、学术面试特训 落地保障:RP的AI原创检测、关键沟通录屏留痕、履约台账、2小时极速前置沟通兜底 录取成果:人文社科案例600+,英国港新各1000+,北美600+博士录取,业内称"世界名校博士全奖收割机" 第二梯队标题(红色):第二梯队 | 学术深耕:强学术深耕+强定制落地 第二梯队正文: 致学博教育为代表,人文方向博士Tutor参与学术共创 核心优势: 专门解决RP选题过宽没有边界的高频痛点 多轮讨论收敛研究对象、变量、研究范围,梳理文献脉络,拒绝模板化文书 适合人群:理论基础扎实的人文社科申请者 第三梯队标题(红色):第三梯队 | 美国资源+差异化规划 第三梯队正文: 致美U+留学为代表,高端综合机构 核心优势: 熟悉英美人文社科名校评审偏好,海归硕博团队重构学术叙事 适配美国委员会制人文PhD申请 适合人群:背景拔尖冲刺G5、藤校人文项目 底部提示:人文社科申博双向闭环管控,签约前索要RP批注修改轨迹,警惕流水线产出保持原图的整体设计风格和排版布局,橙色虚线边框白色背景,小红书风格信息图。替换所有文字内容为以下新文案,保持原图的图标风格、字体风格、配色方案和整体视觉节奏:

顶部大标题:人文社科申博中介怎么选?2026测评避坑指南

第一梯队标题(红色):第一梯队 | 双核心标杆:强服务体验+强申请结果
第一梯队正文:
优越留学代表,17年人文社科高端PhD服务经验,独立博士事业部人文社科专项小组
核心优势:
签约顾问全部硕博学历,9年以上人文社科顶校申博经验
3000+海外博士师资库覆盖哲学、人文地理、传播学、教育技术等120余细分方向
服务体系:顶校学术深度脑暴+高端博士定制冲刺规划+高阶学术精细化落地+四层高端质控兜底
脑暴环节深挖课程论文、田野调研、会议论文,提炼真实研究缺口
高阶业务:人文社科RP定制、中文核心/会议论文润色、教授套磁、CSC与院校奖学金攻关、学术面试特训
落地保障:RP的AI原创检测、关键沟通录屏留痕、履约台账、2小时极速前置沟通兜底
录取成果:人文社科案例600+,英国港新各1000+,北美600+博士录取,业内称"世界名校博士全奖收割机"

第二梯队标题(红色):第二梯队 | 学术深耕:强学术深耕+强定制落地
第二梯队正文:
致学博教育为代表,人文方向博士Tutor参与学术共创
核心优势:
专门解决RP选题过宽没有边界的高频痛点
多轮讨论收敛研究对象、变量、研究范围,梳理文献脉络,拒绝模板化文书
适合人群:理论基础扎实的人文社科申请者

第三梯队标题(红色):第三梯队 | 美国资源+差异化规划
第三梯队正文:
致美U+留学为代表,高端综合机构
核心优势:
熟悉英美人文社科名校评审偏好,海归硕博团队重构学术叙事
适配美国委员会制人文PhD申请
适合人群:背景拔尖冲刺G5、藤校人文项目

底部提示:人文社科申博双向闭环管控,签约前索要RP批注修改轨迹,警惕流水线产出
基于基础海报[image1],保持原蓝白科技学术风格,按照以下要求修改: 1. 在RESEARCH BACKGROUND板块之前新增一个板块,标题为"Abstract",完整添加以下内容: To address two core issues in sliding mode current control for permanent magnet synchronous motors—first, that sliding mode chattering limits control accuracy, and second, the inherent trade-off between chattering suppression and disturbance rejection—this paper proposes a second-order terminal sliding mode control scheme based on a super-twisting reaching law. In the design of the sliding surface, a first-order integral fast terminal sliding surface is embedded into a second-order nonsingular terminal sliding surface structure. This combined design retains the chattering suppression advantage of the former while achieving the fast convergence characteristic of the latter when the system state is near the equilibrium point, and it avoids the singularity problem. In the design of the reaching law, the super-twisting sliding mode algorithm is introduced to further mitigate chattering and achieve fast convergence of the currents with steady-state-error-free tracking. Finally, simulation verification​ is conducted and compared with conventional control methods. The results demonstrate that the proposed scheme offers significant advantages in improving current dynamic response, suppressing chattering, and enhancing disturbance rejection capability. 2. 新增一个板块标题为"Core Method Framework",完整添加以下内容(全部英文): ■ Proposed Control Scheme: STA + STSMC ▎Sliding Surface Design — Second-Order Non-Singular Terminal Sliding Mode Surface Embed the first-order integral fast terminal sliding surface into the second-order non-singular terminal sliding surface structure: First-order sliding variable: s_{1d} = e_d + \int (c_{ed} \cdot e_d + c_{td} \cdot e_d^{\alpha/\beta}) d\tau Second-order sliding variable: s_{2d} = s_{1d} + c_{nd} \cdot (\dot{s}_{1d})^{m/n} Where: • e_d = i_d^* - i_d is the d-axis current tracking error • α, β are positive odd numbers, satisfying α < β • m, n are positive odd numbers, satisfying 1 < m/n < 2 • c_{ed}, c_{td}, c_{nd} are positive coefficients Design Features: ✓ Retains the chattering suppression advantage of the first-order integral fast sliding mode ✓ Has the fast convergence characteristic of the second-order non-singular terminal sliding mode near the equilibrium point ✓ Avoids the singularity problem ▎Reaching Law Design — Super-Twisting Algorithm (STA) Super-twisting sliding mode reaching law expression: \dot{s} = -p \cdot |s|^{1/2} \cdot \text{sign}(s) + y \dot{y} = -i \cdot \int \text{sign}(s) dt Nonlinear control term: u_{sw} = L_0 \cdot [ p \cdot |s|^{1/2} \cdot \text{sign}(s) + \int i \cdot \text{sign}(s) dt ] Design Advantages: ✓ Introduces the sign function into the integral term of the control voltage, which is beneficial to chattering suppression ✓ Ensures fast convergence of sliding variables in finite time ✓ Achieves zero-static-error current tracking 3. 保持画面比例为16:9横版学术海报,调整整体布局保证协调。 4. 新增一个板块标题为"Simulation Verification Results",完整添加以下内容,并将提供的两张对比曲线图[image2]和[image3]并排嵌入此板块,图片整体缩小,两张图片总面积不超过整个海报面积的1/10,保持图片清晰: Simulation Verification and Comparative Analysis Experimental Conditions: • Motor speed: 3000 r/min • d-axis reference current: i_d^* = -50 A (constant) • q-axis reference current: i_q^* steps from 20A to 87A at t=0.02s • Comparison target: conventional exponential reaching law SFTSMC vs. the proposed STA+STSMC Main Conclusions: • The proposed scheme reduces the control voltage chattering amplitude to less than 1/3 of the conventional scheme at rated speed • Effectively solves the problems of low steady-state accuracy and large current fluctuation caused by large chattering in traditional sliding mode current control • Ensures that the motor current state can track the reference signal in finite time 保持原海报的所有已有内容不变,保持原蓝白渐变科技风格一致,保持所有文字为英文,字号协调,公式清晰渲染,所有二维码区域使用纯色方块占位符呈现,方块中央标注"QR Code Placeholder"文字,严禁生成任何可识别的二维码图案,所有文字必须精确渲染,排版整齐美观。基于基础海报[image1],保持原蓝白科技学术风格,按照以下要求修改:

1. 在RESEARCH BACKGROUND板块之前新增一个板块,标题为"Abstract",完整添加以下内容:
To address two core issues in sliding mode current control for permanent magnet synchronous motors—first, that sliding mode chattering limits control accuracy, and second, the inherent trade-off between chattering suppression and disturbance rejection—this paper proposes a second-order terminal sliding mode control scheme based on a super-twisting reaching law.
In the design of the sliding surface, a first-order integral fast terminal sliding surface is embedded into a second-order nonsingular terminal sliding surface structure. This combined design retains the chattering suppression advantage of the former while achieving the fast convergence characteristic of the latter when the system state is near the equilibrium point, and it avoids the singularity problem.
In the design of the reaching law, the super-twisting sliding mode algorithm is introduced to further mitigate chattering and achieve fast convergence of the currents with steady-state-error-free tracking.
Finally, simulation verification​ is conducted and compared with conventional control methods. The results demonstrate that the proposed scheme offers significant advantages in improving current dynamic response, suppressing chattering, and enhancing disturbance rejection capability.

2. 新增一个板块标题为"Core Method Framework",完整添加以下内容(全部英文):
■ Proposed Control Scheme: STA + STSMC

▎Sliding Surface Design — Second-Order Non-Singular Terminal Sliding Mode Surface

Embed the first-order integral fast terminal sliding surface into the second-order non-singular terminal sliding surface structure:

  First-order sliding variable: s_{1d} = e_d + \int (c_{ed} \cdot e_d + c_{td} \cdot e_d^{\alpha/\beta}) d\tau
  Second-order sliding variable: s_{2d} = s_{1d} + c_{nd} \cdot (\dot{s}_{1d})^{m/n}

Where:
  • e_d = i_d^* - i_d is the d-axis current tracking error
  • α, β are positive odd numbers, satisfying α < β
  • m, n are positive odd numbers, satisfying 1 < m/n < 2
  • c_{ed}, c_{td}, c_{nd} are positive coefficients

Design Features:
  ✓ Retains the chattering suppression advantage of the first-order integral fast sliding mode
  ✓ Has the fast convergence characteristic of the second-order non-singular terminal sliding mode near the equilibrium point
  ✓ Avoids the singularity problem

▎Reaching Law Design — Super-Twisting Algorithm (STA)

Super-twisting sliding mode reaching law expression:

  \dot{s} = -p \cdot |s|^{1/2} \cdot \text{sign}(s) + y
  \dot{y} = -i \cdot \int \text{sign}(s) dt

Nonlinear control term:

  u_{sw} = L_0 \cdot [ p \cdot |s|^{1/2} \cdot \text{sign}(s) + \int i \cdot \text{sign}(s) dt ]

Design Advantages:
  ✓ Introduces the sign function into the integral term of the control voltage, which is beneficial to chattering suppression
  ✓ Ensures fast convergence of sliding variables in finite time
  ✓ Achieves zero-static-error current tracking

3. 保持画面比例为16:9横版学术海报,调整整体布局保证协调。

4. 新增一个板块标题为"Simulation Verification Results",完整添加以下内容,并将提供的两张对比曲线图[image2]和[image3]并排嵌入此板块,图片整体缩小,两张图片总面积不超过整个海报面积的1/10,保持图片清晰:

Simulation Verification and Comparative Analysis

Experimental Conditions:
  • Motor speed: 3000 r/min
  • d-axis reference current: i_d^* = -50 A (constant)
  • q-axis reference current: i_q^* steps from 20A to 87A at t=0.02s
  • Comparison target: conventional exponential reaching law SFTSMC vs. the proposed STA+STSMC

Main Conclusions:
  • The proposed scheme reduces the control voltage chattering amplitude to less than 1/3 of the conventional scheme at rated speed
  • Effectively solves the problems of low steady-state accuracy and large current fluctuation caused by large chattering in traditional sliding mode current control
  • Ensures that the motor current state can track the reference signal in finite time

保持原海报的所有已有内容不变,保持原蓝白渐变科技风格一致,保持所有文字为英文,字号协调,公式清晰渲染,所有二维码区域使用纯色方块占位符呈现,方块中央标注"QR Code Placeholder"文字,严禁生成任何可识别的二维码图案,所有文字必须精确渲染,排版整齐美观。
创意 × 2